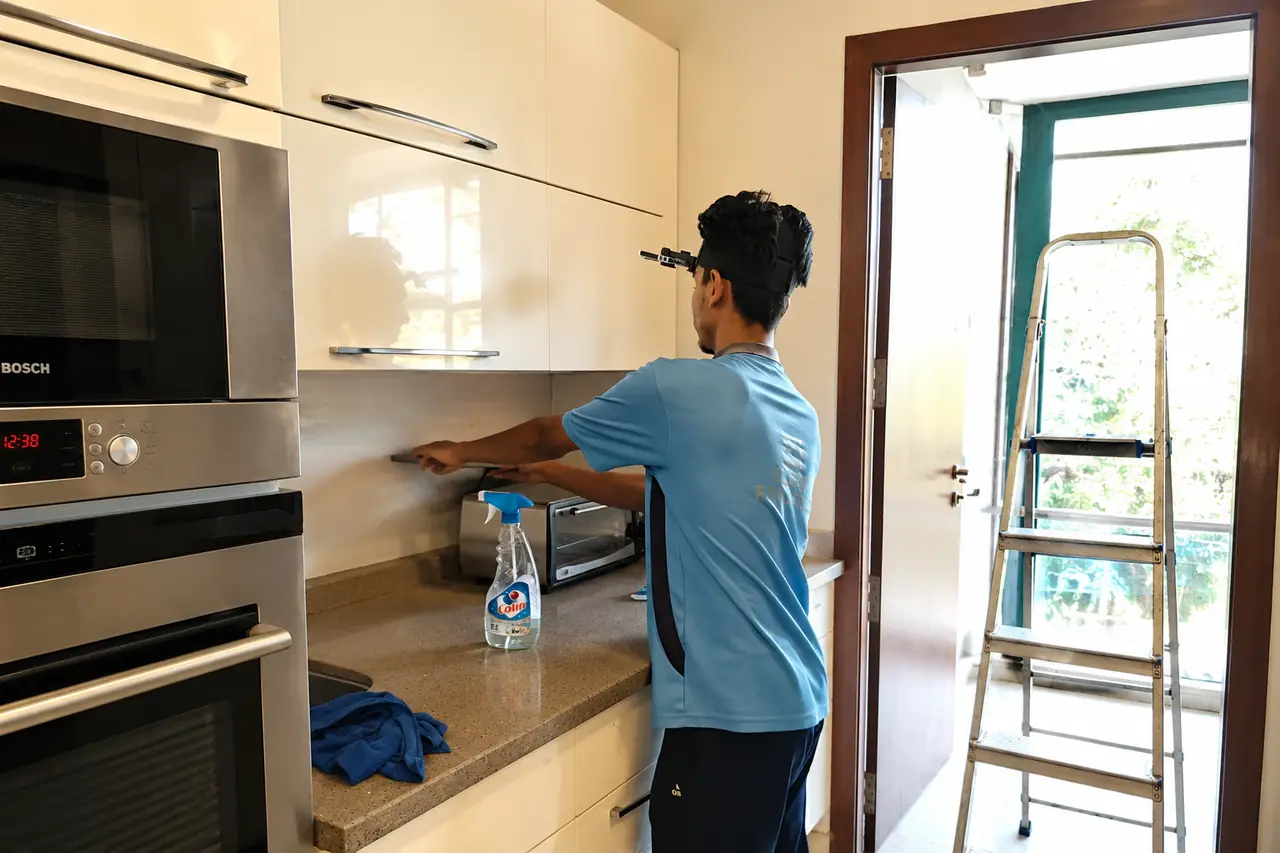
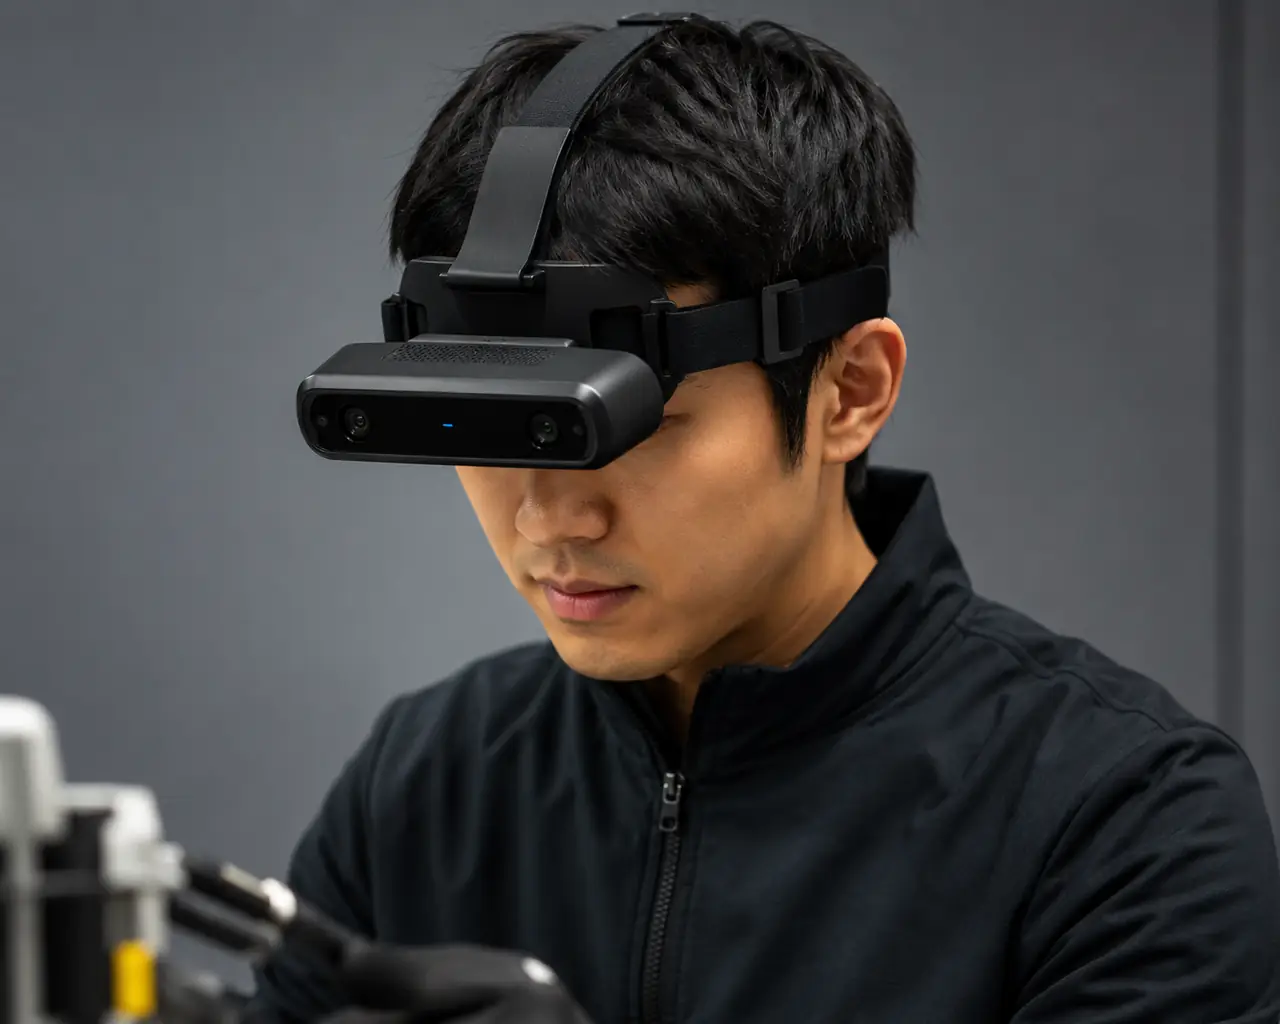
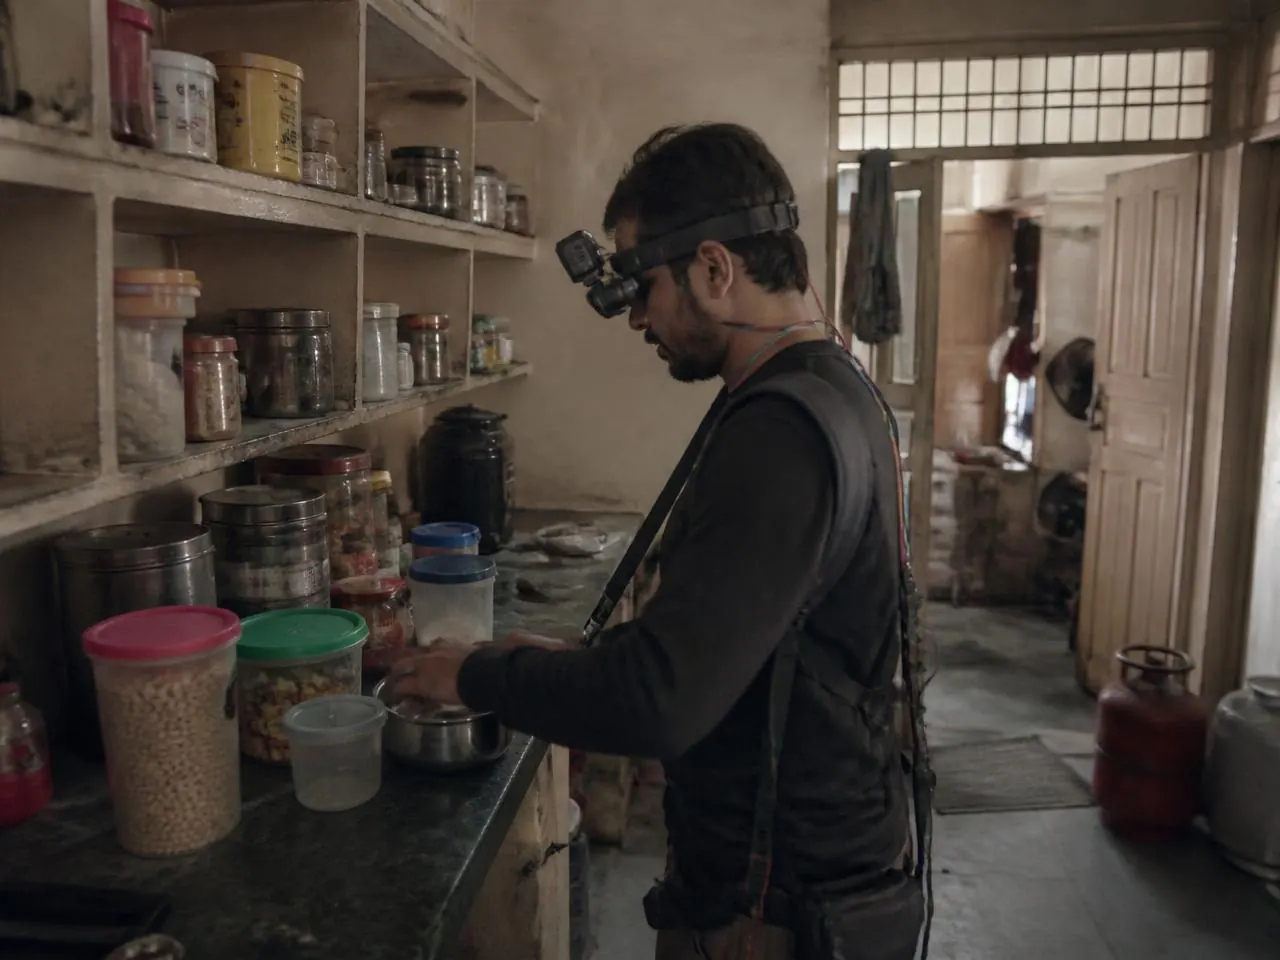
Collect large-scale Ego data and human demonstration datasets using head-mounted cameras. We handle end-to-end data collection, operations, annotation and QA services for Physical AI, humanoid robotics, dexterous manipulation, embodied AI and robot foundation models.
Choose the task, hardware, environment, and production-ready data across real-world environments—powered by India’s largest Human Operations platform.
Awign is India’s largest human operations company with 1.5M+ workers, operations across 1,000+ cities, and the ability to manage complex work at large scale.
For robotics companies, we turn this workforce and operating infrastructure into a dedicated data production layer for egocentric video, sensor-based capture, teleoperation, and semantic annotation. You bring the robotics problem. We bring the people, places, SOPs, execution, and quality control.
See how Awign builds robotics data production lines — from SOP design and environment setup to worker deployment, capture, QA, and annotation.
1.5M+1,500,000
workers
0+
cities
10K+10,000
Hrs Videos per day
98%
Labeling accuracy
Our Offerings
Choose the Data Pipeline Your Robot Needs
Start with one data collection workflow or combine multiple capabilities into a dedicated robotics data production line.
Ego Vision
Monocular RGB egocentric video at scale
First-person RGB video of humans performing real-world tasks using monocular camera rigs. Ideal for large-scale human activity data, imitation learning, embodied AI, humanoid robotics, and manipulation datasets.
Capture setup
Monocular RGB camera rigs, phones, or client-specified RGB setups.
Deliverables
Raw RGB video, task metadata, environment metadata, QC status, and optional annotation.
Add-ons
VLM-assisted labels, HITL QA, captions, task segmentation, and 3D hand pose estimation.
Egocentric capture using LiDAR devices, stereo headsets, or custom stereo camera rigs to generate stronger depth and 3D hand-object understanding than monocular RGB. Ideal for depth estimation, 3D hand pose estimation, hand-object tracking, spatial reasoning, and manipulation research.
Ego Depth Ultra
Absolute 3D hand pose ground truth with wrist camera
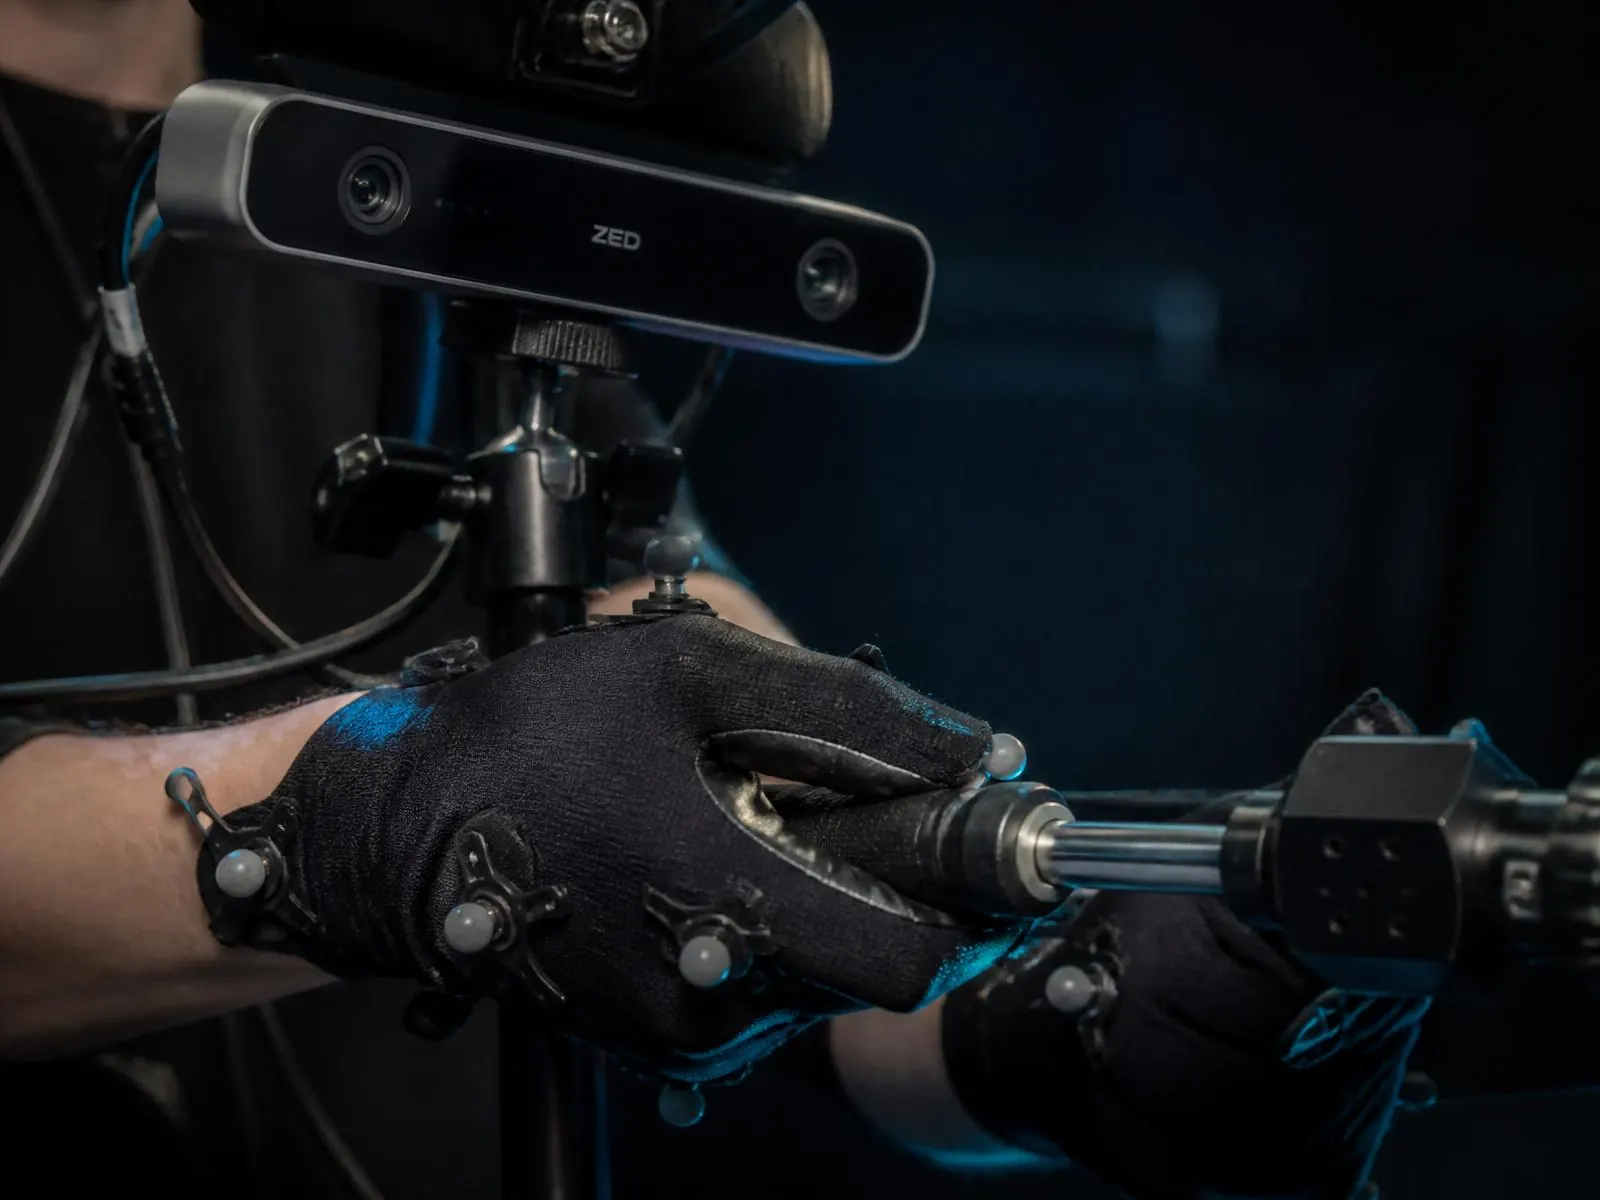
Ego camera capture combined with wrist camera/mocap gloves to provide true hand pose ground truth, including key-points that are visually occluded in the egocentric camera view. Ideal for high-precision hand pose datasets, dexterous manipulation, benchmark creation, policy learning, and model evaluation.
Semantic Annotation
Turn robotics videos into structured training data
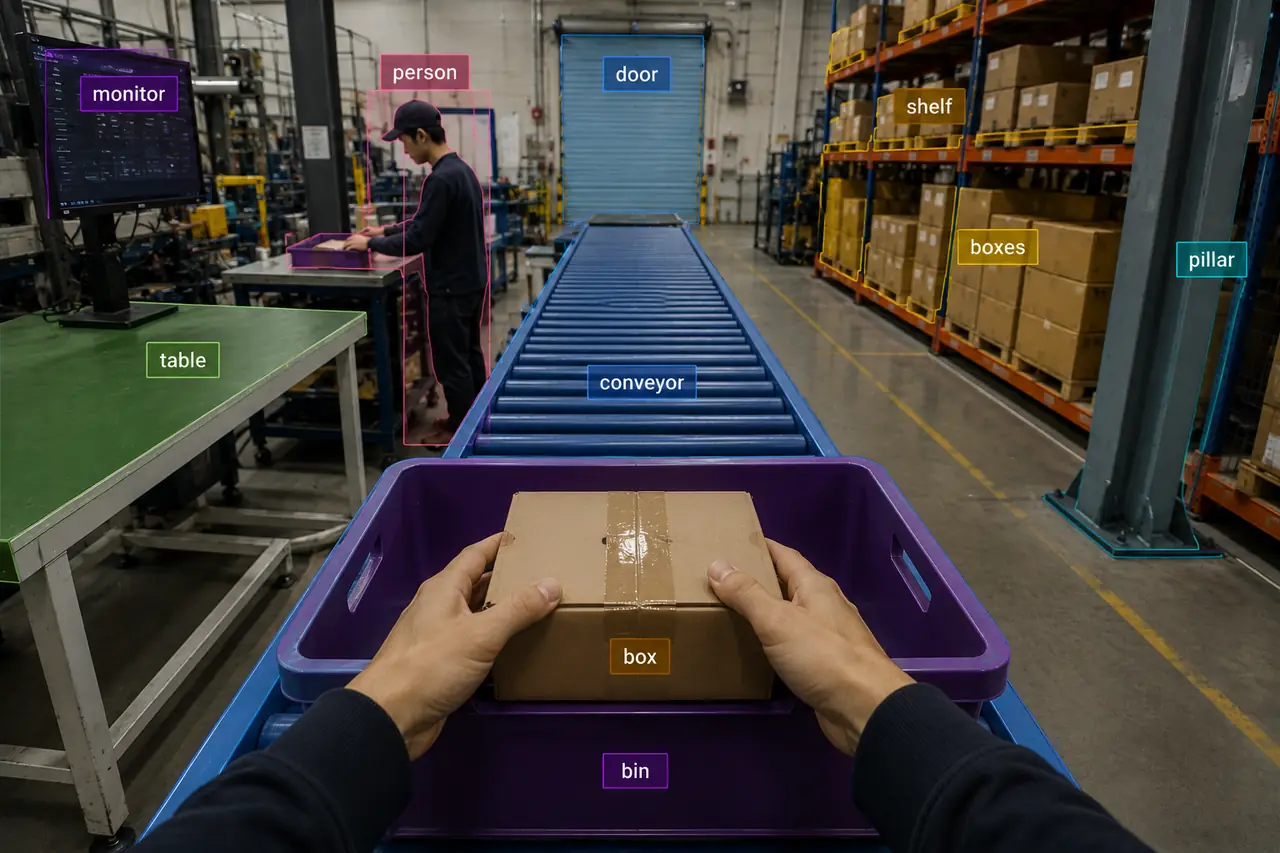
Awign segments, labels, captions, rates, and validates ego, teleop, robot, and policy videos using VLM-assisted workflows and human-in-the-loop review. Ideal for long-horizon robotics videos, egocentric datasets, policy evaluation, failure analysis, and action-level training data.
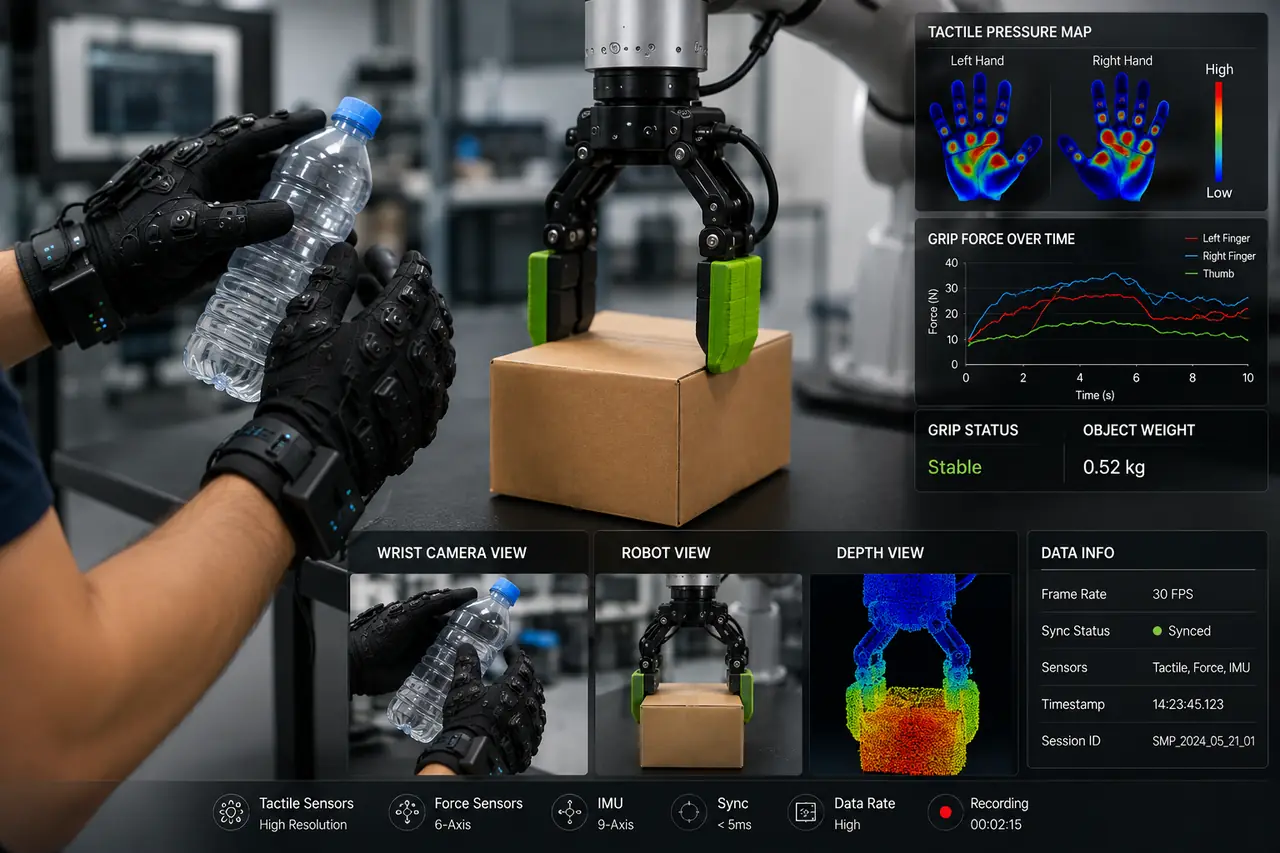
Ego Touch
Tactile and contact-rich robotics data
Capture how humans touch, grasp, press, hold, lift, move, and release objects using tactile and contact-sensing hardware. Ideal for grasping, force-aware manipulation, tactile learning, dexterity, and contact prediction.
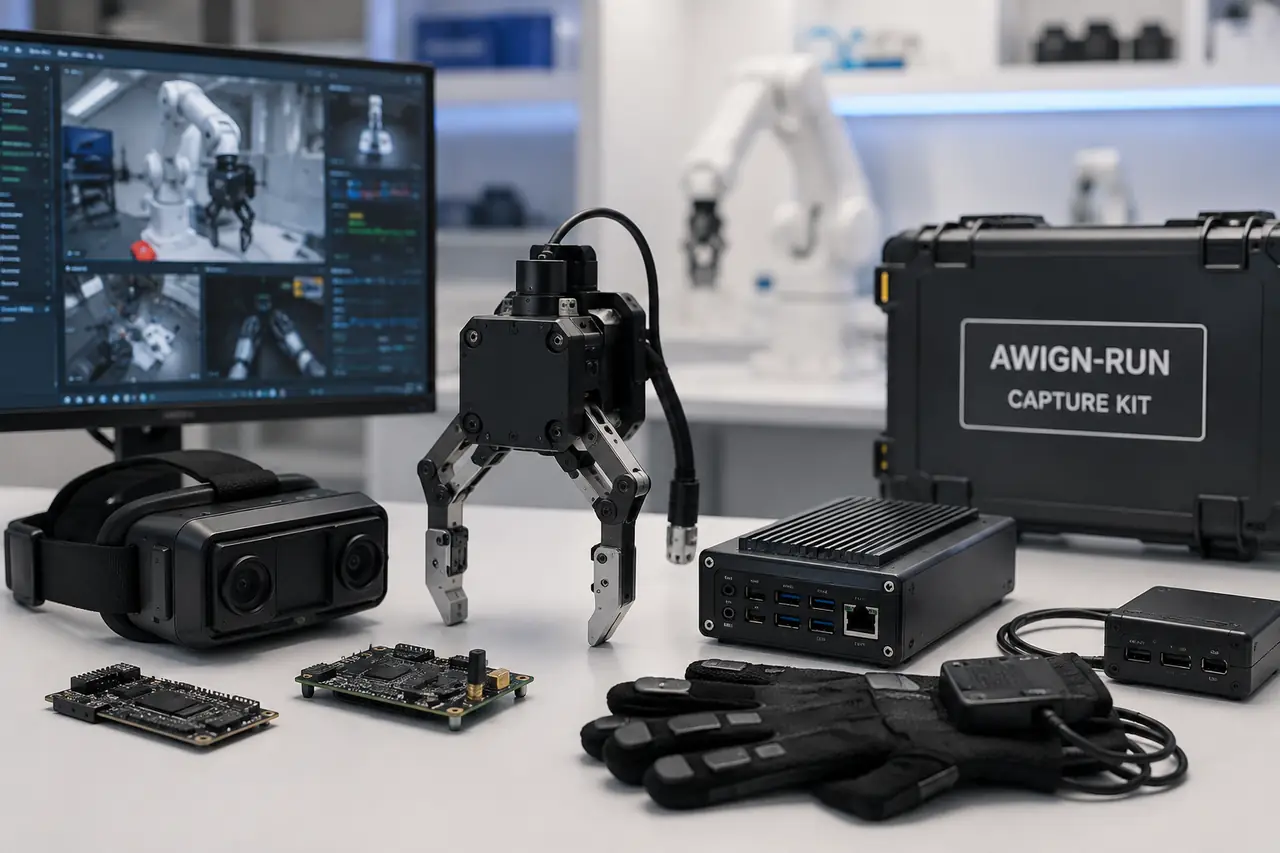
BYOS
Your proprietary hardware. Awign-run operations.
For robotics teams with unique hardware, confidential capture systems, custom rigs, robot interfaces, or proprietary workflows. You bring the stack; Awign finds or recreates the right environment, deploys trained workers, runs the SOP, and manages large-scale operations in India.
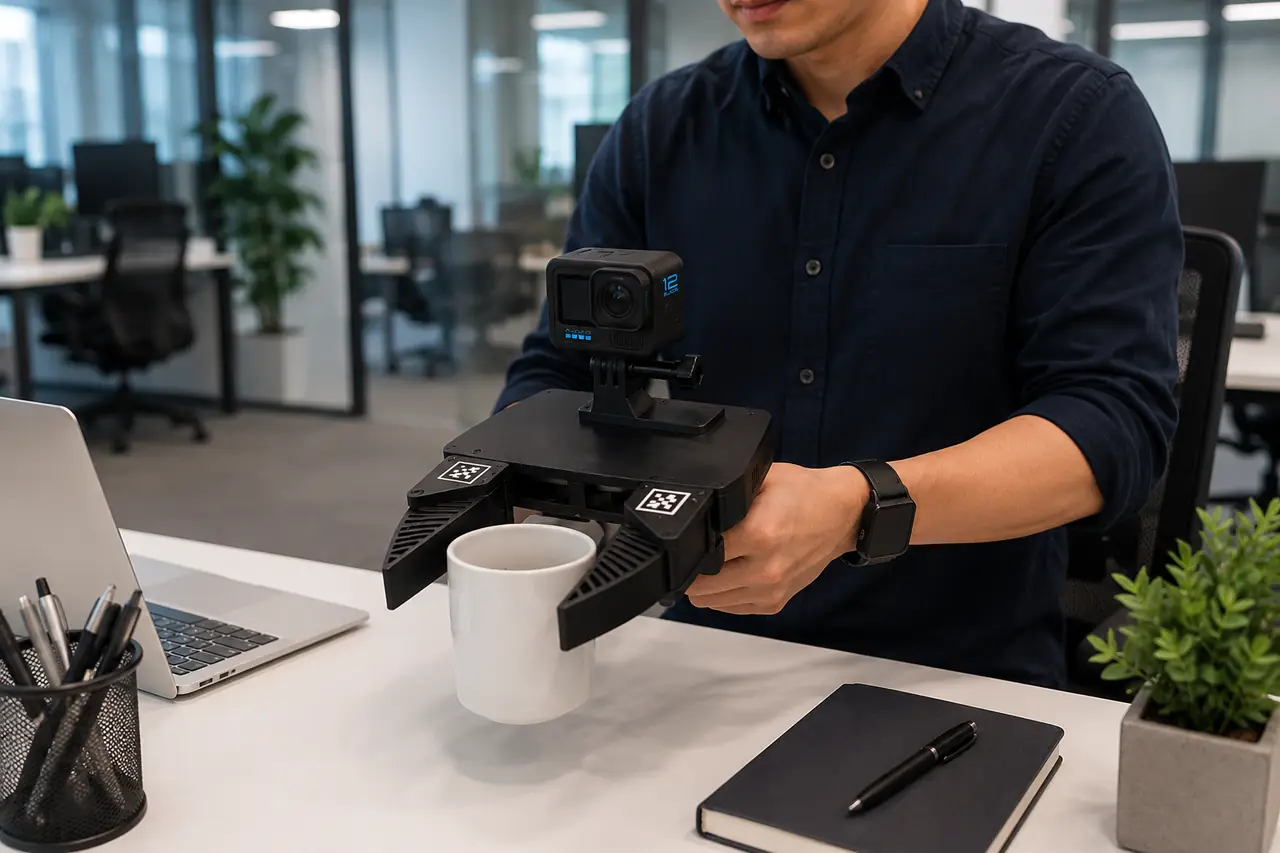
Gripper Vision
Gripper-centric human demonstration data
Human demonstration data for robotic grasping, manipulation, and object interaction across UMI, 2-finger, and custom grippers.
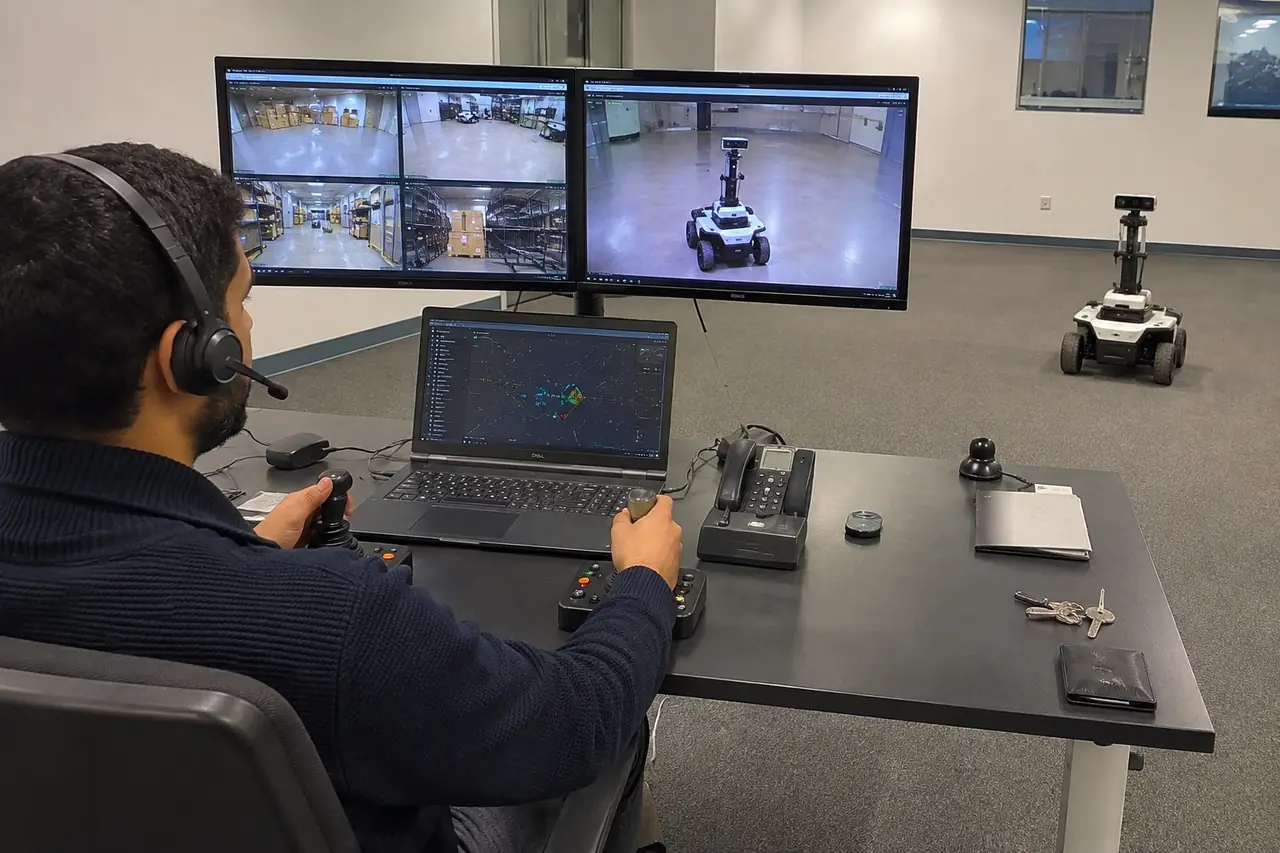
Teleoperations
Remote operators for robot control and data generation
Awign provides trained remote operators to control robots, run demonstrations, monitor systems, handle interventions, and generate policy data for robot learning, remote manipulation, simulation control, fleet monitoring, and policy evaluation.
Environments
Real environments. Recreated environments. Custom environments.
Robotics models need data from the places where they will actually operate. Awign can source, partner with, or recreate environments across India.
Indian homes
Daily household tasks, kitchens, bedrooms, living rooms, storage areas, appliances, and real-world clutter.
Western-style homes
India-based homes or recreated spaces designed to resemble US/EU residential environments.
We protect your data with secure storage, controlled access, PII protection, and privacy-first collection practices. From consent and data capture to storage and delivery, we follow strict security protocols to keep your data safe and confidential.
How it works
From Requirements to Production-Ready Data
From setup to delivery, we manage your robotics data pipeline at scale.
Step 1
Define the requirement
Tasks, hardware, environment, output format, volume, and quality bar.
Step 2
Design the SOP
We convert your requirement into worker instructions, QA rules, escalation paths, and delivery specs.
Step 3
Set up the environment
We source, partner with, or recreate the required environment in India.
Step 4
Deploy the workforce
Workers are trained, scheduled, monitored, and managed by Awign.
Batch-level QA, issue tracking, rework loops, metadata, and structured delivery.
Build Your Robotics Data Pipeline in India
Start with a pilot. Scale into a dedicated production line for egocentric video, depth data, mocap ground truth, tactile data, teleoperation, BYOS, or semantic annotation.
Get pricing, sample datasets, and a project plan within 24 hours.
Frequently Asked Questions
Get clear answers to help you choose the right egocentric data collection service and scale your AI and robotics projects with confidence.
Where can robotics companies get Physical AI training data?
Awign provides Physical AI training data collection services for robotics companies, AI labs, and humanoid robotics teams. We collect real-world human demonstrations, egocentric video, multimodal sensor data, and task-specific datasets for robot learning, embodied AI, Physical AI, and robotics model training.
What is egocentric data collection for robotics and Physical AI?
Egocentric data collection captures first-person video and sensor data from a human perspective using wearable, head-mounted, wrist-mounted, or other camera configurations. This data helps AI systems learn human actions, object interactions, manipulation behaviors, environments, and real-world task execution.
What types of robotics training data can Awign collect?
Awign can collect egocentric video, (first-person video/POV), human demonstration data, manipulation data, multimodal datasets, multi-camera recordings, and sensor data. Collection can be customized based on the required robotics tasks, environments, hardware, metadata, data formats, and quality specifications.
Can Awign collect multimodal data for Physical AI and VLA models?
Yes. Awign can create multimodal Physical AI datasets combining visual, motion, interaction, and sensor information. Depending on project requirements, datasets can include stereo cameras, wrist cameras, IMU sensors, tactile sensors, robotic grippers, and UMI systems for Vision-Language-Action (VLA), embodied AI, and robot learning.
What cameras and sensors can Awign use for robotics data collection?
Awign supports a range of robotics data collection hardware, including custom monocular cameras, stereo cameras, iPhones, Android phones, wrist cameras, wearable cameras, GoPro cameras, IMU sensors, tactile sensors, robotic grippers, and UMI systems. Hardware configurations can be selected based on the training signals and dataset requirements.
Can Awign collect human demonstrations for robot manipulation and imitation learning?
Yes. Awign can collect human demonstration and fine-grained manipulation data for tasks such as grasping, picking and placing, pouring, cutting, assembling, folding, fastening, cooking, cleaning, tool use, and other human-object interactions. These demonstrations can support imitation learning, robot manipulation, robot learning, and Physical AI training.
Can Awign provide training data for humanoid robots and embodied AI?
Yes. Awign can design data collection programs for humanoid robots, embodied AI, robot learning, and Physical AI. Programs can capture human activities, demonstrations, and interactions across real-world environments to help AI models learn physical tasks, human actions, and human-object interactions.
What environments can Awign cover for robotics data collection?
Awign can collect real-world robotics data across household and residential environments, retail, commercial spaces, warehouses, manufacturing facilities, workshops, agriculture, and workplaces. Data collection can be organized around specific environments, scenarios, task taxonomies, and environmental conditions.
How does Awign ensure robotics data quality, privacy, and security?
Awign combines automated validation and human quality assurance to evaluate framing, motion quality, task compliance, duration, synchronization, and metadata completeness. Collection workflows can also incorporate participant consent, privacy controls, PII protection, bystander privacy protocols, and client-specific data security requirements.
Can Awign scale custom Physical AI and robotics data collection programs?
Yes. Awign can design and scale custom Physical AI and robotics data collection programs based on task, environment, geography, hardware, sensors, dataset volume, metadata schema, and quality requirements. Programs can combine egocentric video, stereo and wrist cameras, IMU, tactile, gripper, UMI, and other multimodal data to create specialized datasets for robotics, humanoid robots, Physical AI, embodied AI, and VLA models.