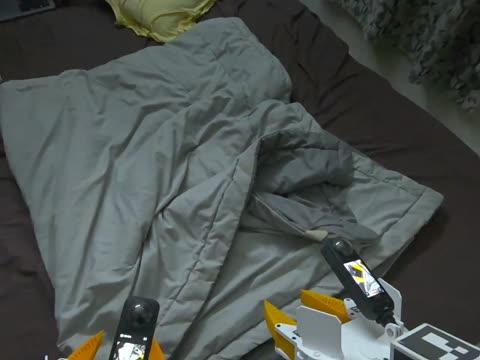
 00:43
UMI Gripper
Household
1280×960 per Meta eye; 1920×1440 supplied composite · ~29.98–30 fps Meta streams; 30 fps supplied composite · 1.02 GB
 Robotics Data
ROBOTICS DATA SAMPLE LIBRARY
Explore sample videos across our robotics data SKUs. Preview, check file contents and download the original files.
High-quality real-world data
Captured across diverse environments for training robust robotics models.
Browse By Environment
Left and right gripper-camera views of unloading a washing machine.
Sample files
Supporting metadata · Camera videos.
Original sample files (zip)
00:43Household
1280×960 per Meta eye; 1920×1440 supplied composite · ~29.98–30 fps Meta streams; 30 fps supplied composite · 1.02 GB
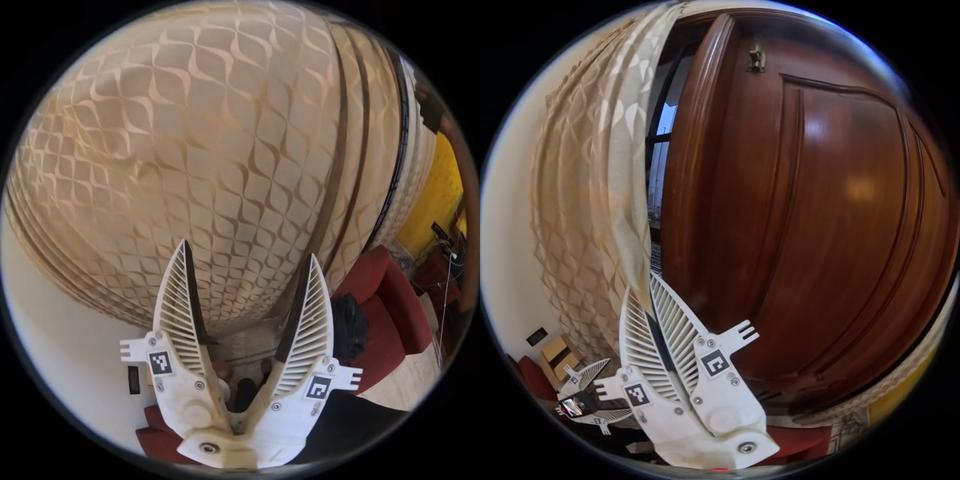 00:35
Household
2880×2880 per camera · 29.97 fps · 1.22 GB
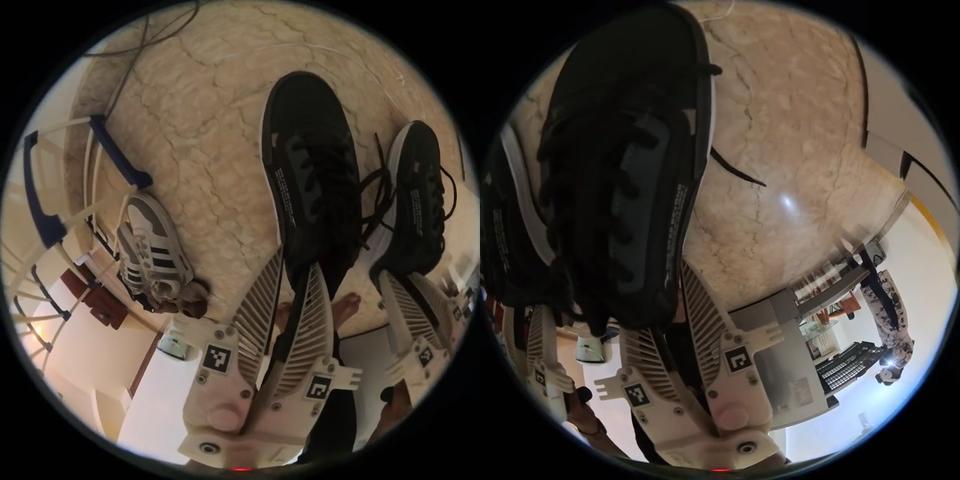 01:21
Household
2880×2880 per camera · 29.97 fps · 2.80 GB
 01:02
Household
2880×2880 per camera · 29.97 fps · 2.13 GB
 00:46
Household
2880×2880 per camera · 29.97 fps · 1.65 GB
 01:07
Household
2880×2880 per camera · 29.97 fps · 2.29 GB
 01:23
Household
2880×2880 per camera · 29.97 fps · 2.84 GB
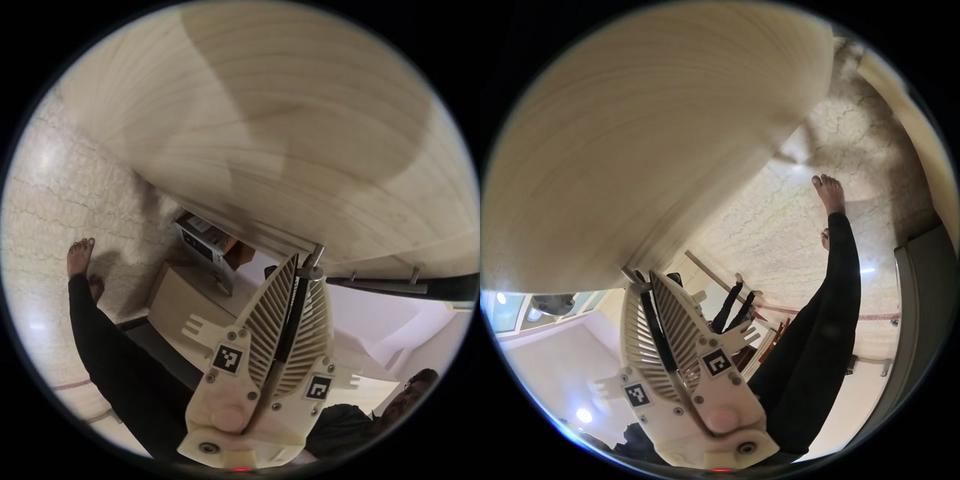 01:33
Household
2880×2880 per camera · 29.97 fps · 3.21 GB
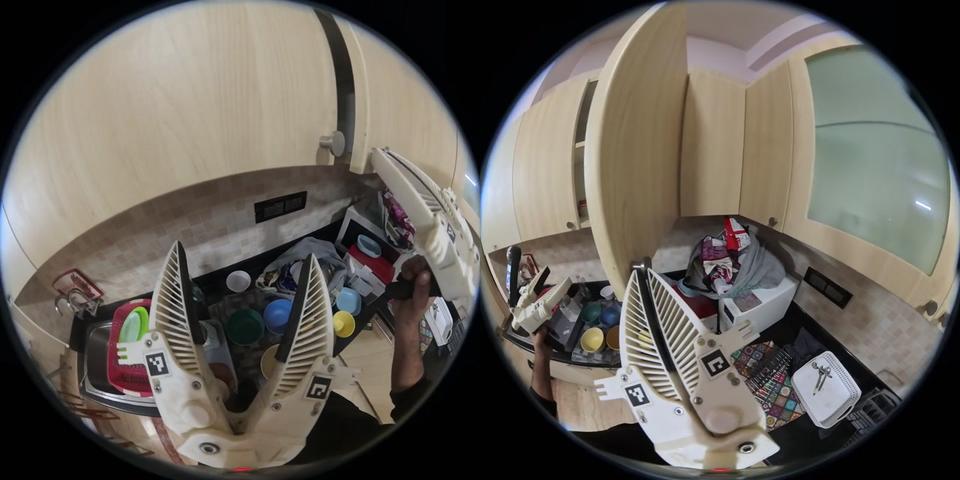 01:11
Household
2880×2880 per camera · 29.97 fps · 2.43 GB
We offer custom data collection across devices, environments and tasks.
Talk to Our TeamCustom devices • Environments • Tasks • Data collection