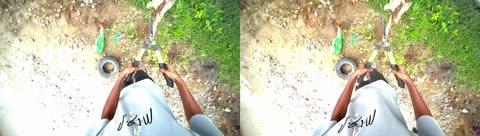
 03:37
Stereo RGB-IMU
Household
3840×1080 combined; 1920×1080 per eye · 30 fps · 1.57 GB
 Robotics Data
ROBOTICS DATA SAMPLE LIBRARY
Explore sample videos across our robotics data SKUs. Preview, check file contents and download the original files.
High-quality real-world data
Captured across diverse environments for training robust robotics models.
Browse By Environment
Pick up the clean utensils from the dishwasher and place them neatly outside, arranging them appropriately in their designated places.
Raw MP4 Video
Original recorded video file
Video Timestamps
Timestamp Data
Camera Metadata
Device, camera and capture settings
Motion Data
IMU motion
Depth Meta Data
Original sample files (zip)
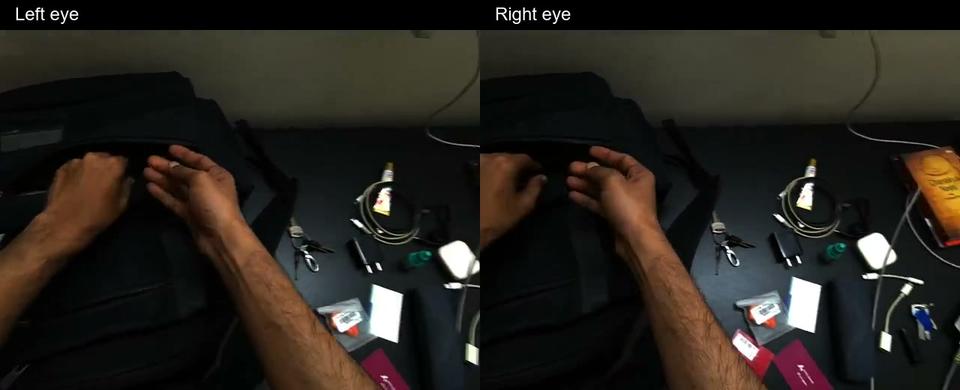
03:37Household
3840×1080 combined; 1920×1080 per eye · 30 fps · 1.57 GB
 03:22
Household
2560×960 stereo; 1280×960 per eye · 30 fps · 726.69 MB
 00:43
Household
1920×1440 · 30 fps · 137.32 MB
 03:22
Household
2560×960 stereo; 1280×960 per eye · 30 fps · 910.74 MB
 01:15
Household
3840×1080 combined; 1920×1080 per eye · 30 fps · 208.92 MB
We offer custom data collection across devices, environments and tasks.
Talk to Our TeamCustom devices • Environments • Tasks • Data collection